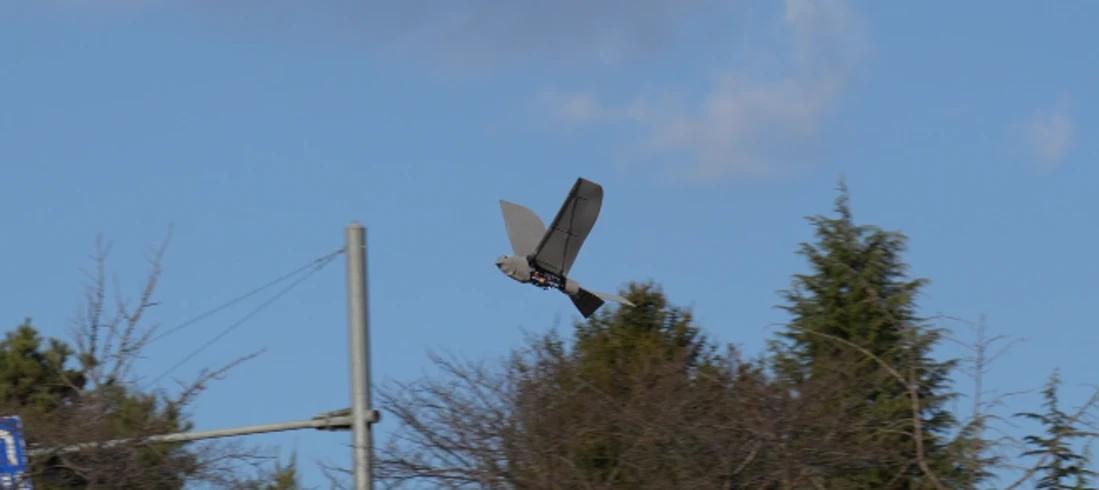
KAIST Robotic Falcon with Simple Wing (KRoFalcon-S) is an ornithopter prototype developed at KAIST SSHS Lab to validate ORNISP’s forward-flight trim predictions. Measured flight speed and estimated angle of attack were compared with predictions at matching flapping and elevon settings. The aircraft also demonstrated Pixhawk-based autonomous loiter flight.
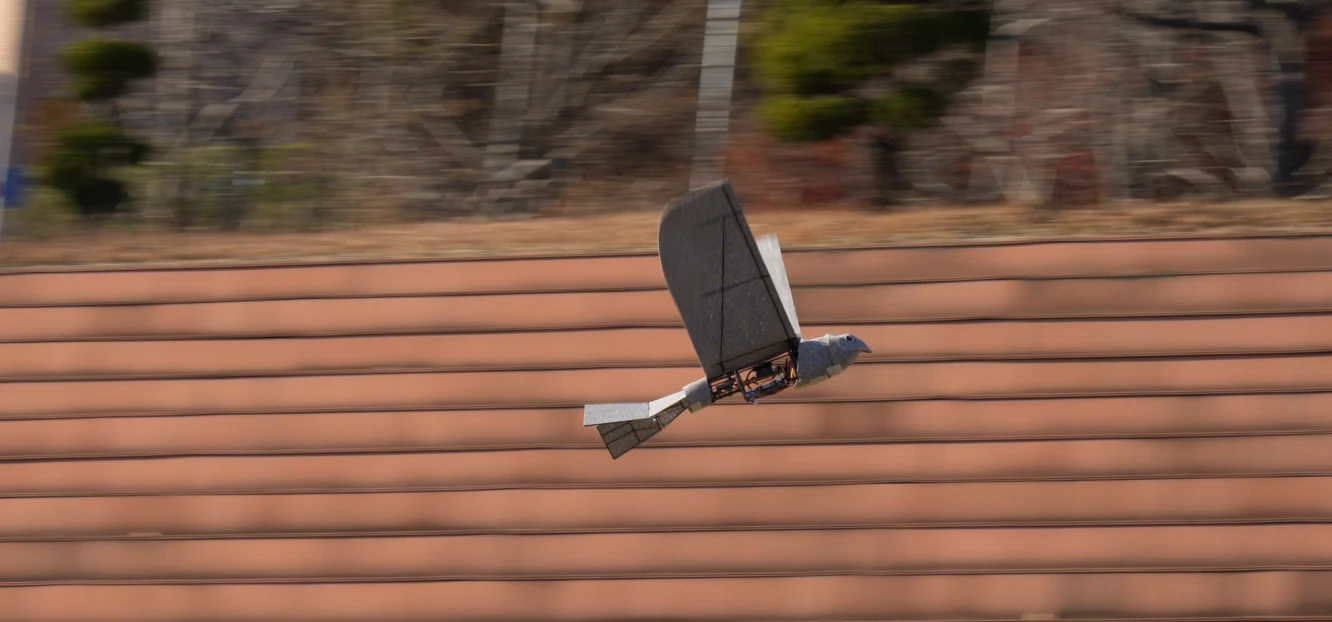
Vehicle Overview
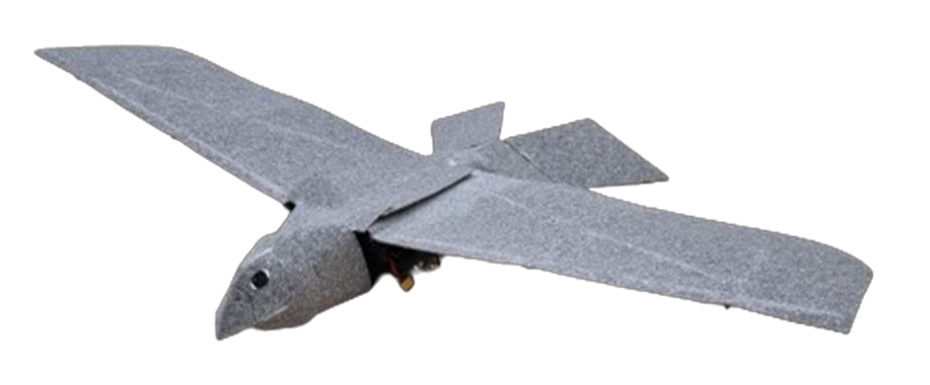
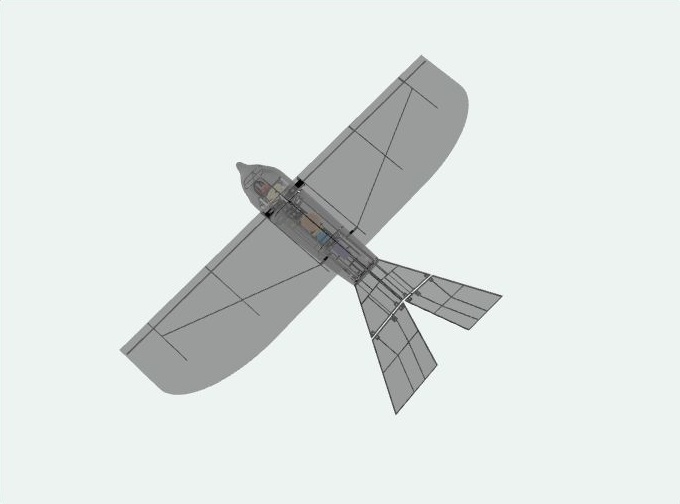
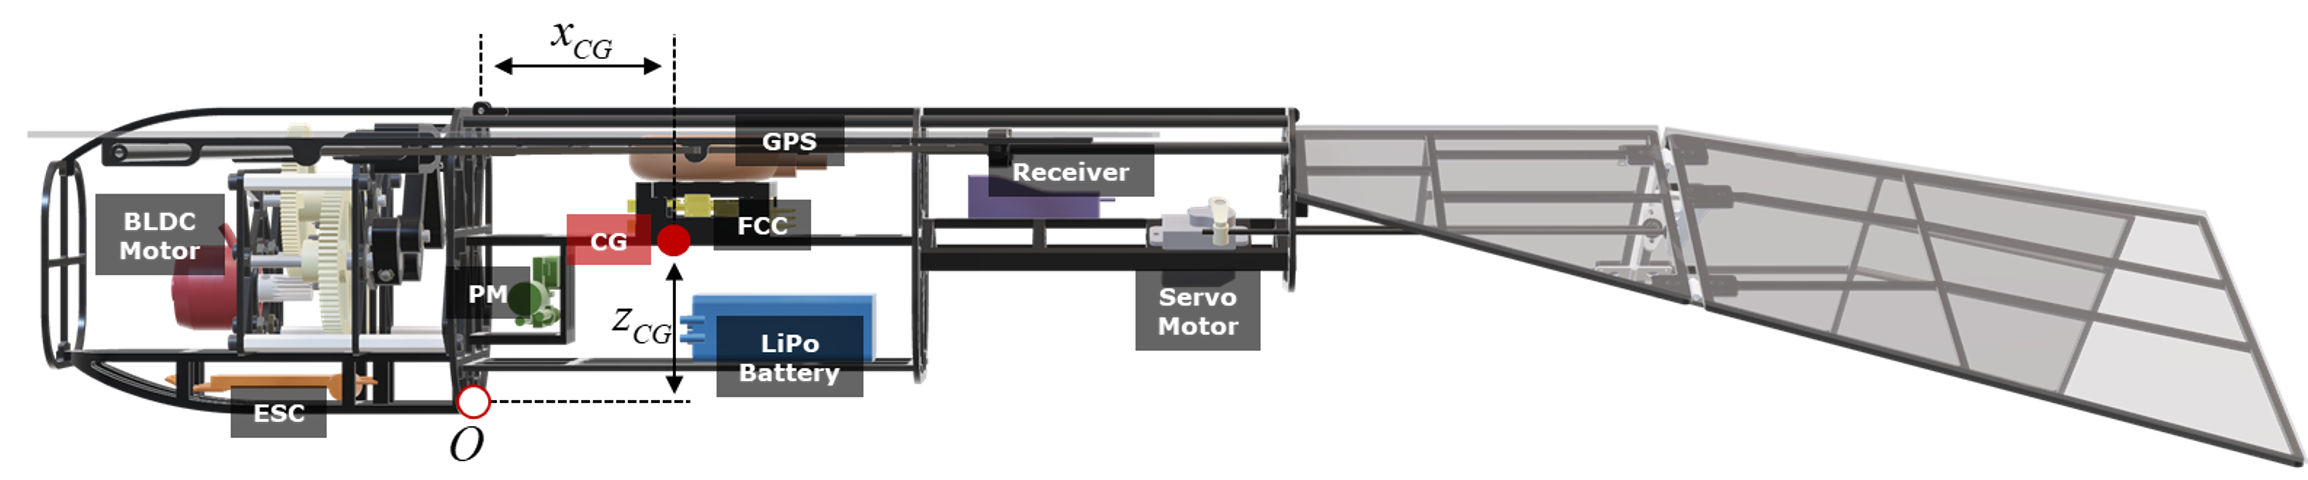
A motor drives a crank-rocker mechanism that converts continuous rotation into wing flapping. The main wings have no folding joints, and tail elevons control the aircraft’s attitude.
| Specification | Value |
|---|---|
| Wingspan | 1,200 mm |
| Body length | 700 mm |
| Weight including battery | ≈620 gf |
| Flight computer | Pixhawk 4 Mini |
Avionics
The Pixhawk 4 Mini uses inertial and GPS measurements to estimate the aircraft’s motion. An electronic speed controller drives the flapping motor, while servo motors actuate the tail elevons.
Flight Demonstration
After a manual climb, KRoFalcon-S switched to autonomous loiter mode and tracked a commanded circular path using Pixhawk and PX4.